Research on spacecraft pose estimation using event-based sensor data, with reproducible training, inference, and evaluation pipelines.
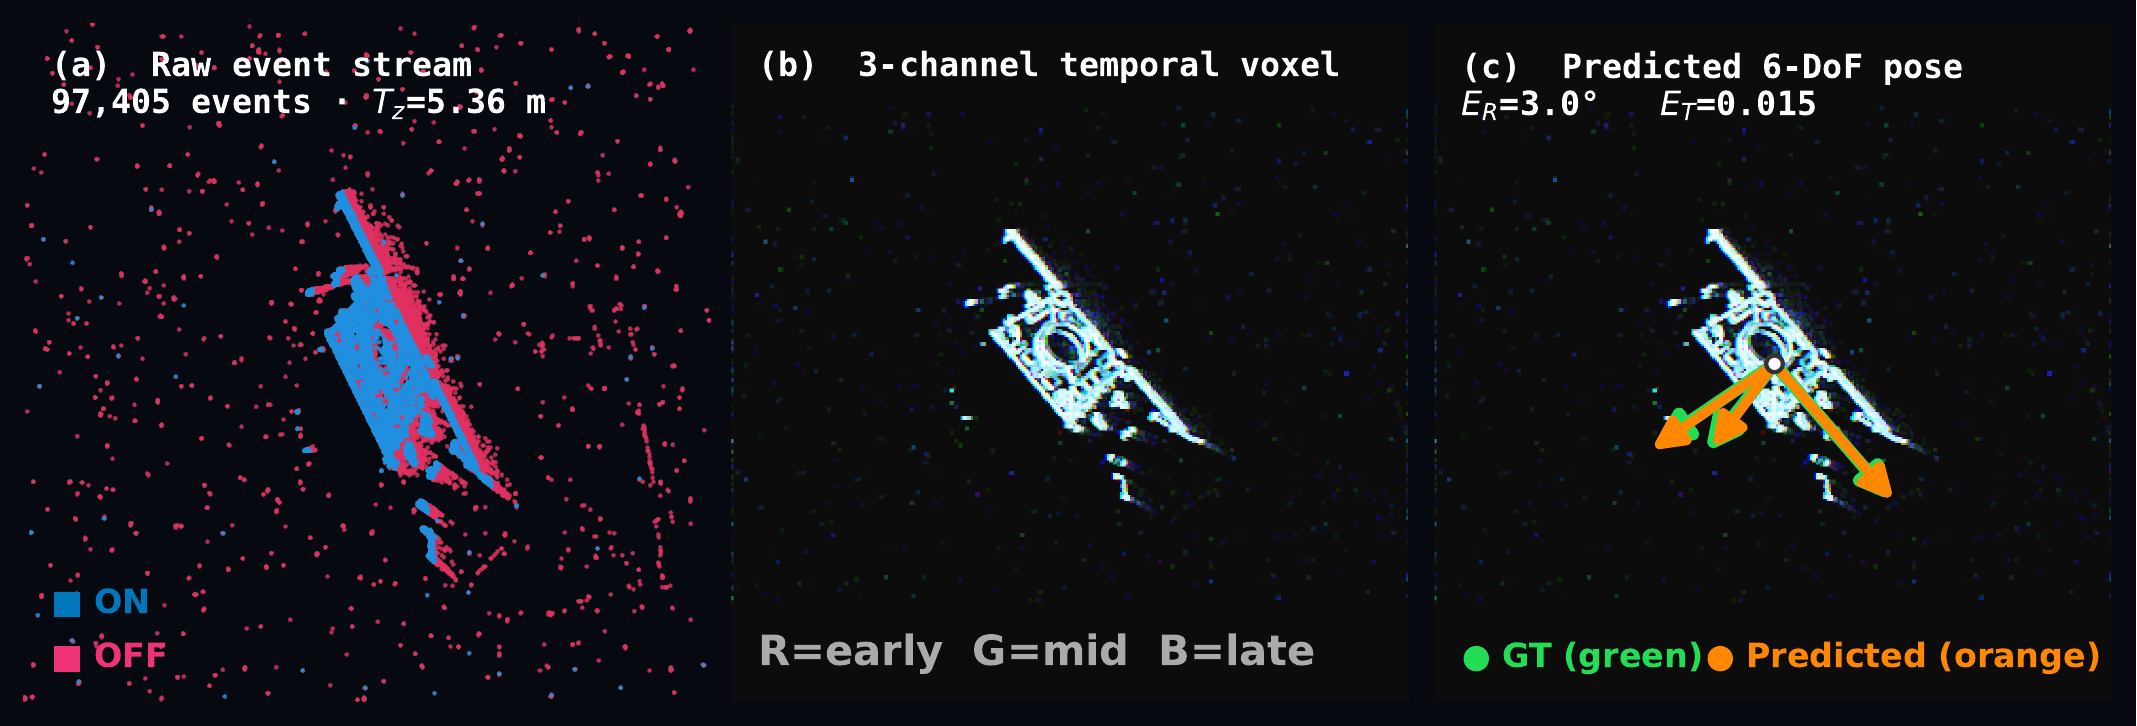
The public SPADES pipeline converts event streams into image representations and uses global and local views to estimate translation and rotation.
Representation
Events are aggregated into a three-channel image representation. Global frames retain scene context; local crops emphasize the spacecraft.
Architecture
An EfficientNet-V2-S translation branch and a ResNet-50 rotation branch with attention predict position and a normalized quaternion.
Evaluation
Domain-aware augmentation, preprocessing consistency, and systematic error analysis help examine the gap between synthetic data and real sensor observations.
Team result
Contributed to an ASU perception project that placed 4th out of 59 teams in the AI4SPACE 2026 challenge, as reported in my resume.